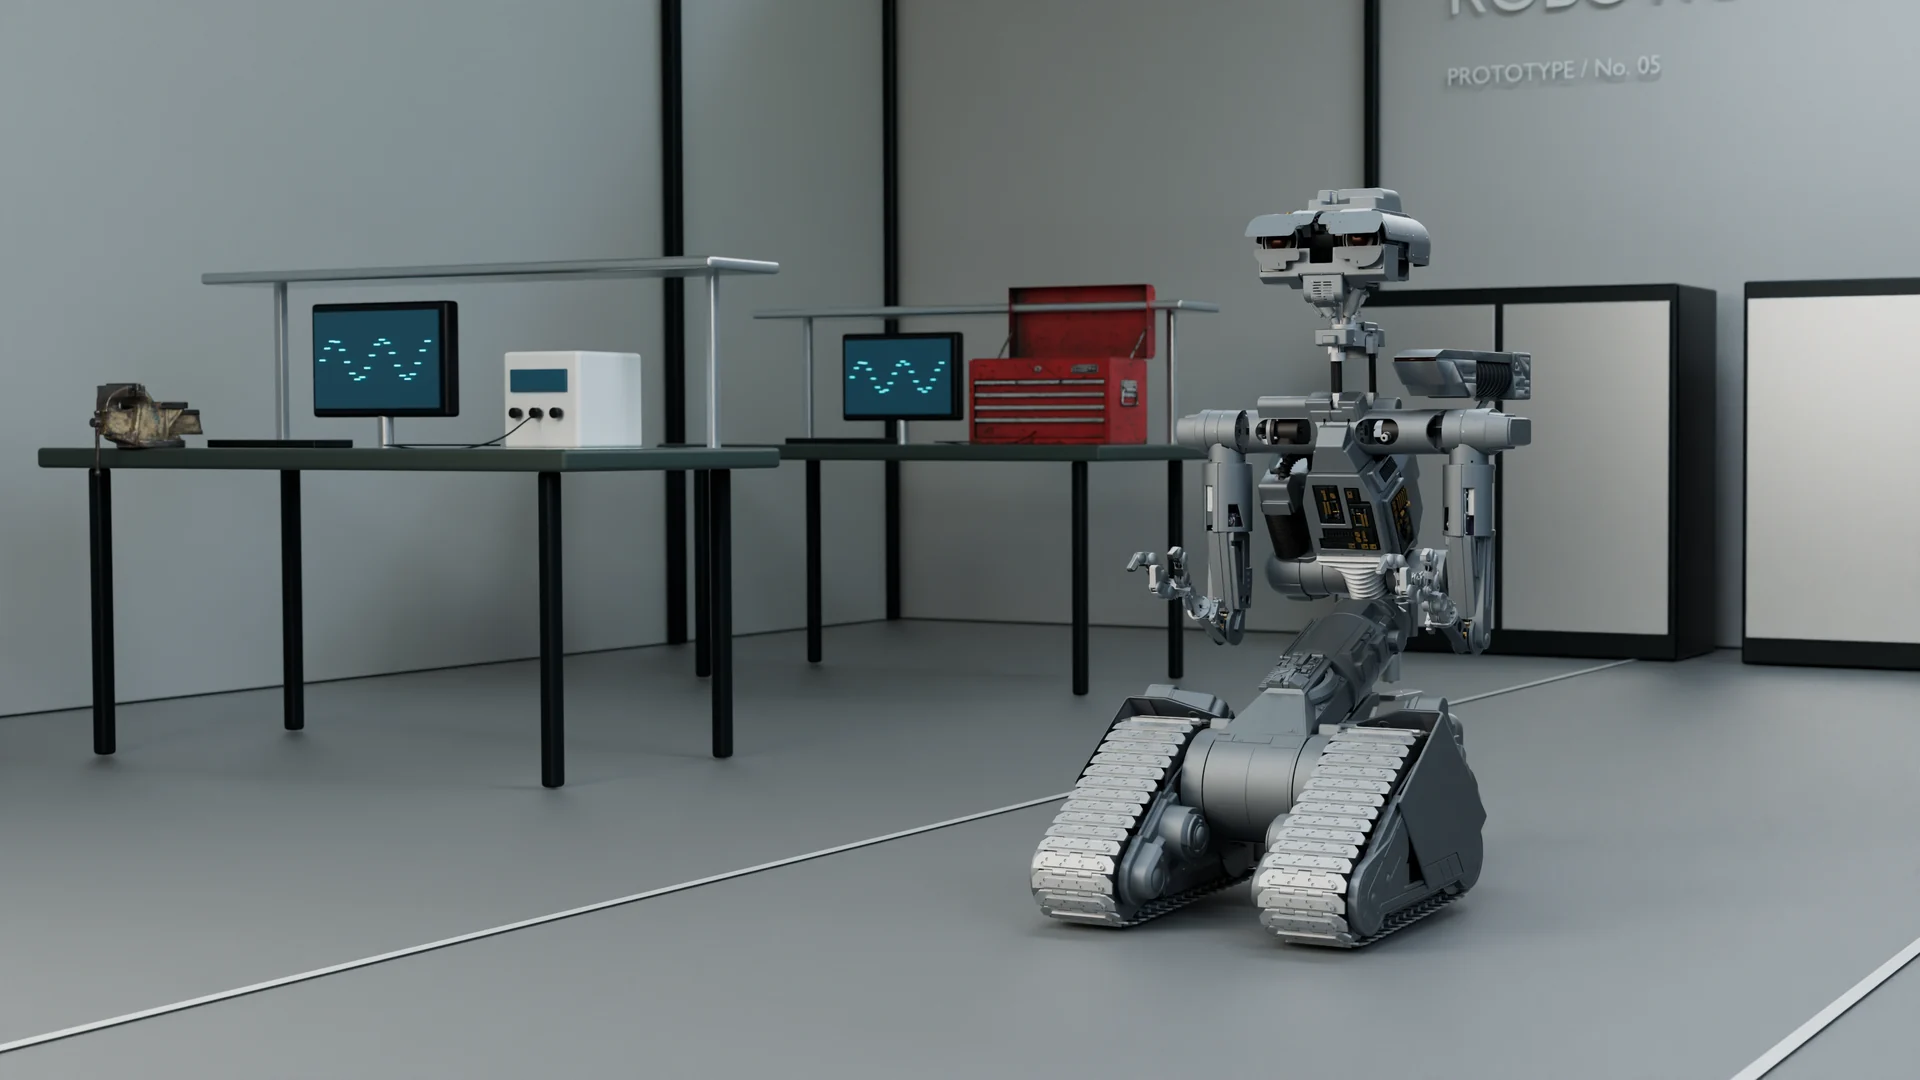
PERSONAL PROJECT / IN DEVELOPMENT
Numero 5.From cinema to the lab.
A full-size replica, modified and redesigned components, and an architecture planned for onboard AI.
01 / THE OBJECTIVE
Giving shape to a Robotics Engineering project.
Simone Renzi aims to build a full-size Numero 5 replica, faithful to the appearance of the robot from Short Circuit, with a local artificial intelligence system. The project accompanies his master’s programme in Computer Engineering, specialising in Robotics, and is intended to lead towards his final thesis.
The challenge is to reconcile the outer form with everything the robot must contain and move: structure, transmissions, wiring, sensors, computing and power. Each choice must fit into the assembly and have a path to verification.
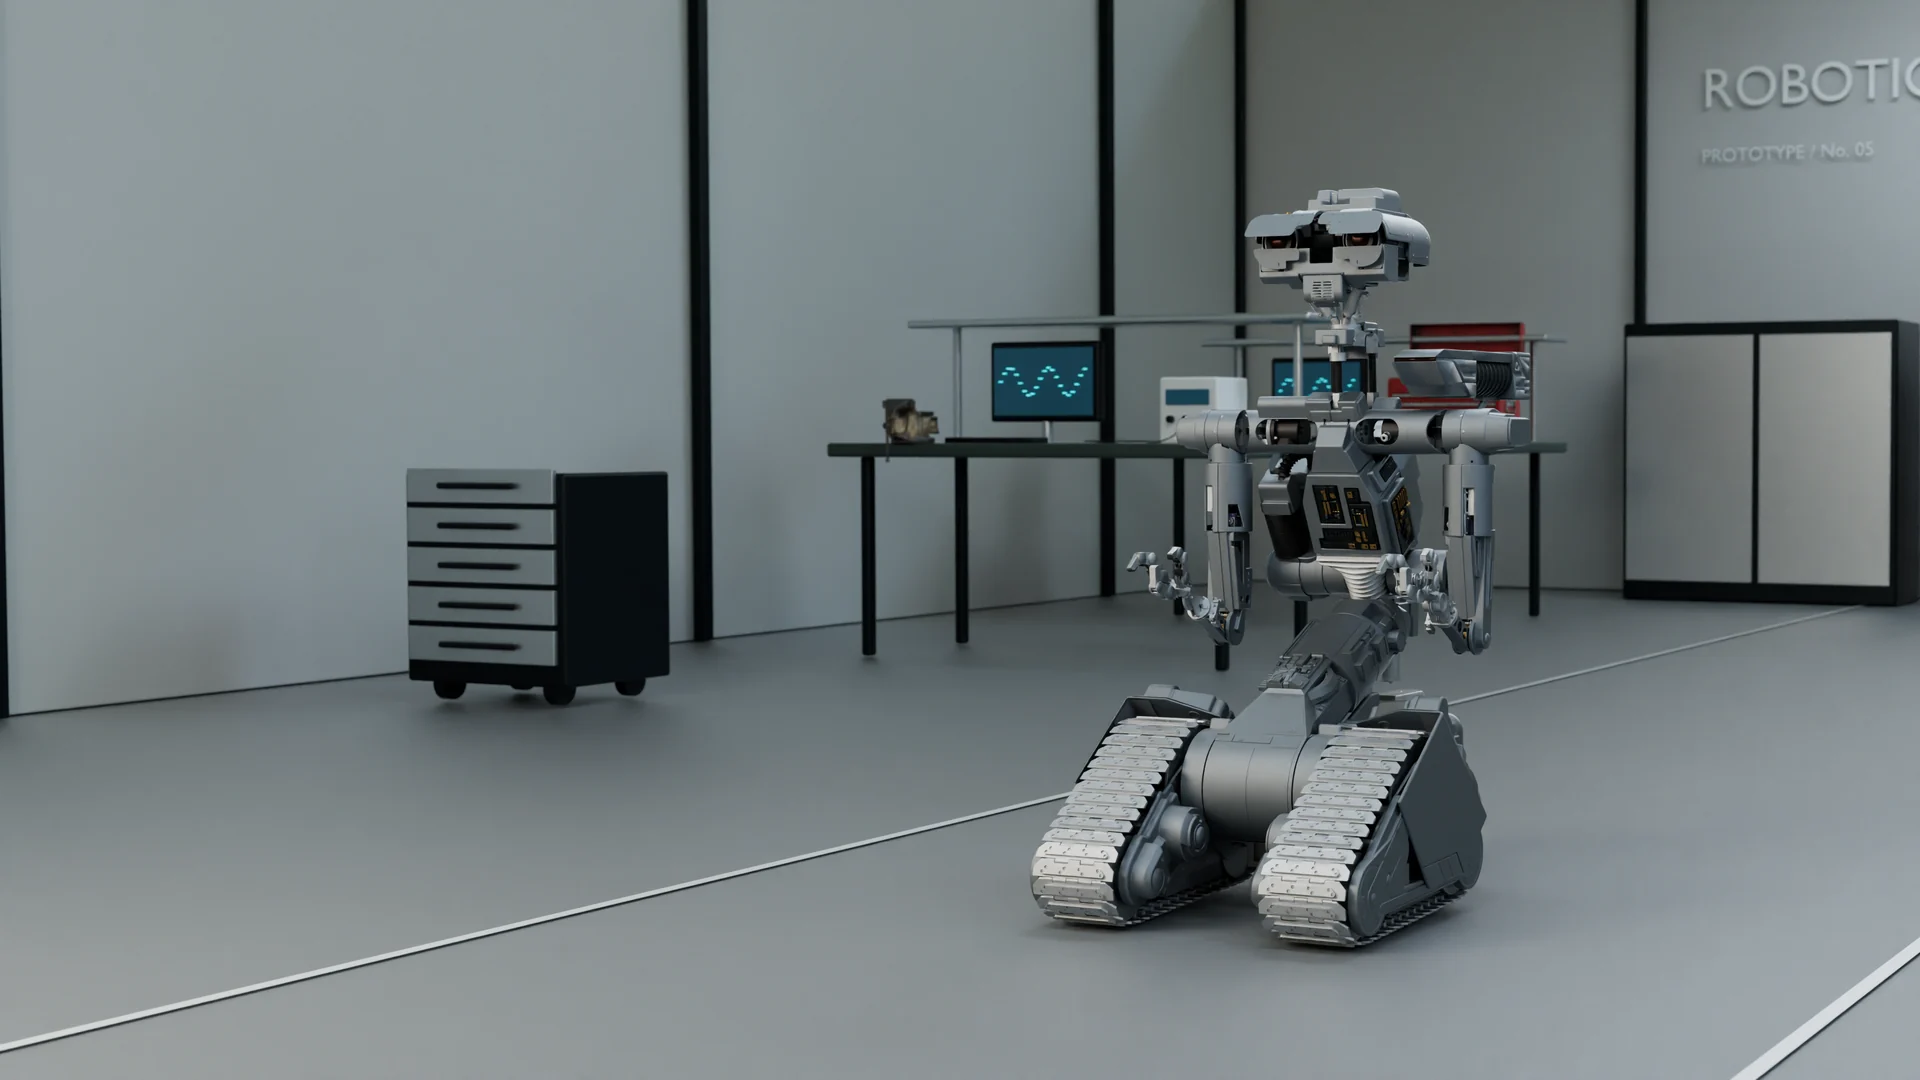
This page documents the development phase. The images show the CAD model; the complete physical robot and autonomous capabilities are project objectives.
02 / ORIGINS AND PERSONAL CONTRIBUTION
A shared foundation, an evolving project.
OpenSAINT / Input Inc.
OpenSAINT was an essential starting point: its CAD files and documentation provided a fundamental reference for approaching a complex assembly. Simone Renzi acknowledges that contribution and retains links to the original sources.
The OpenSAINT project ↗Simone Renzi’s work on the robot
On this foundation Simone Renzi has modified many components and completely redesigned some of them. The work includes rebuilding and integrating assemblies in Fusion, revising mechanical interfaces, kinematics and geometry checks. It also includes designing the architecture for onboard AI.
The journal examines individual changes so that the origin of the foundation and Simone Renzi’s personal contribution remain clear.
03 / MECHANICS
From component to assembly.
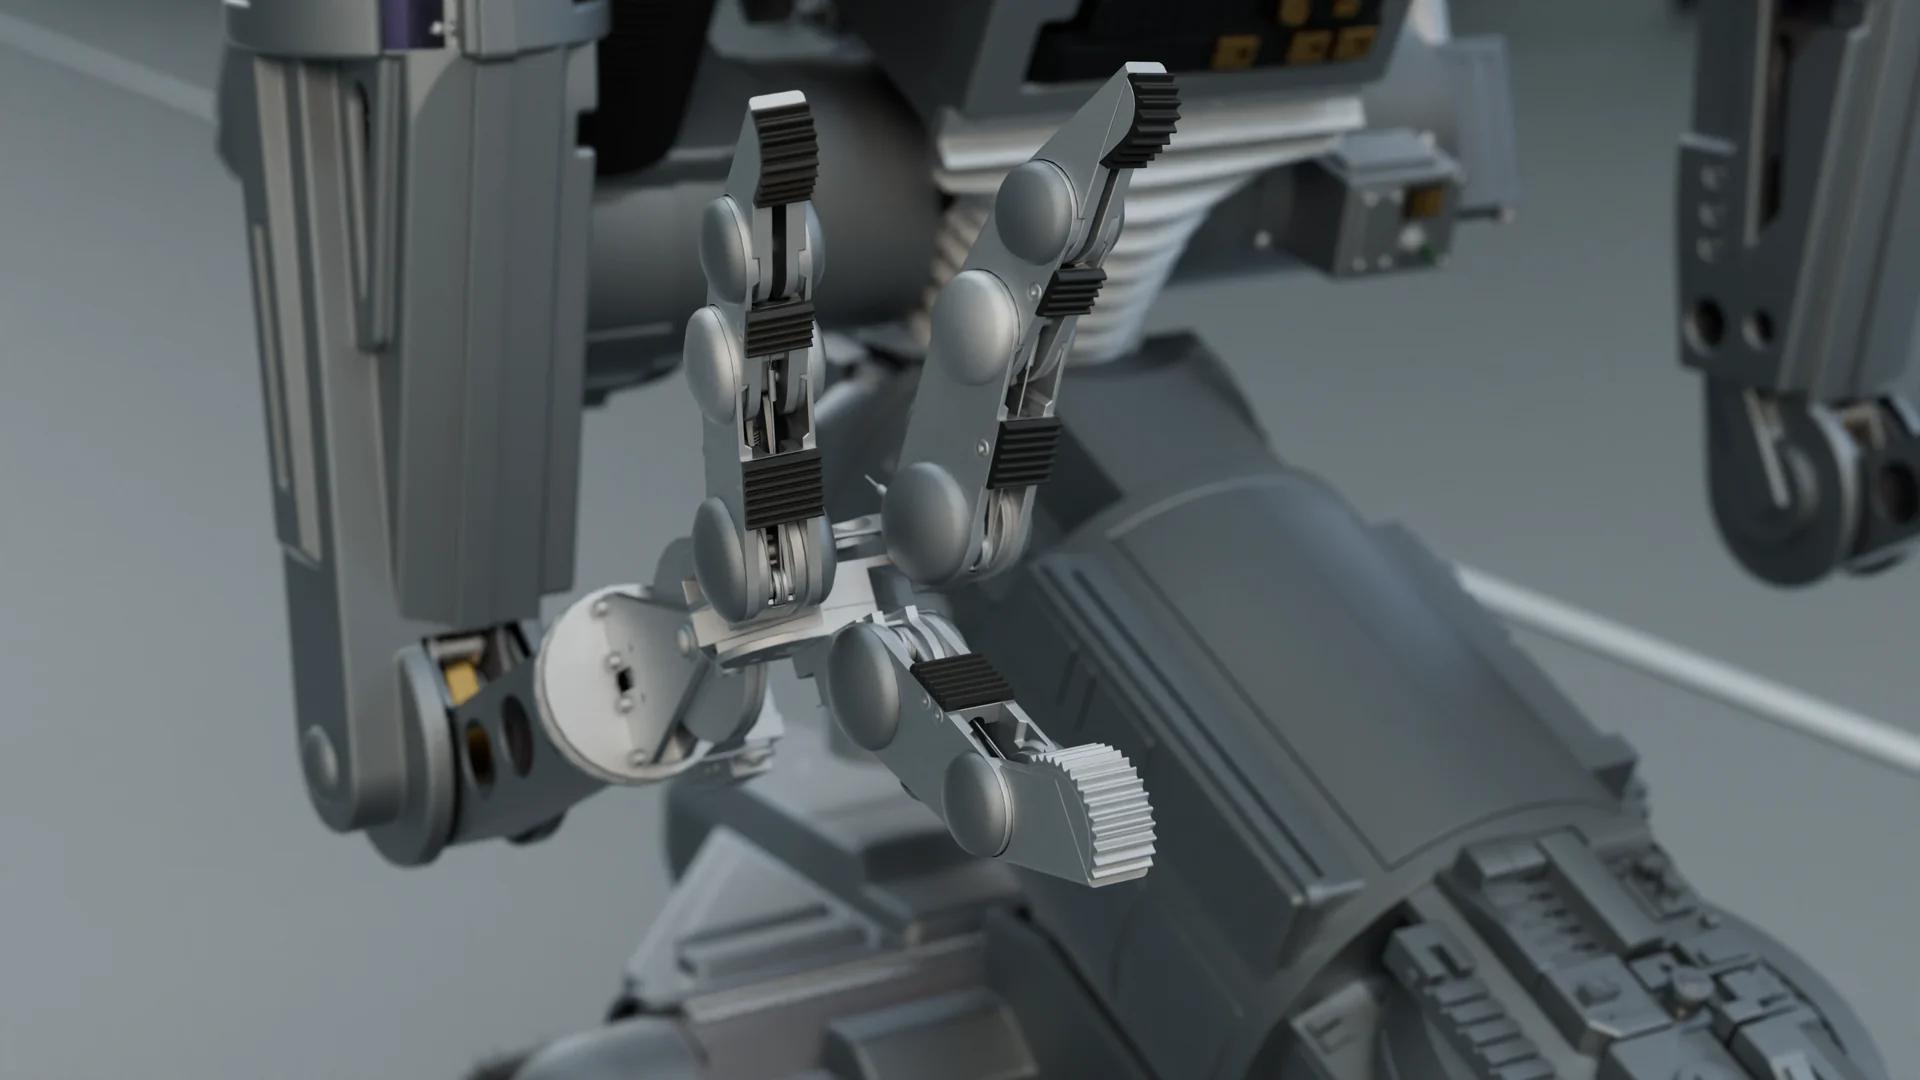
Head, neck, torso, arms and tracked base are studied as parts of one system. The work includes organising components, checking imported geometry and defining motion relationships between modules.
Recent revisions focus on torso interfaces, the elbow–wrist–hand chain and finger components. CAD checks help verify integration; sizing, load capacity, materials and manufacturability require dedicated checks before construction.
04 / ELECTRONICS AND CONTROL
From computation to motion.
The planned architecture separates AI computation from motion management. The Mac Studio will communicate with a central controller, which will coordinate microcontrollers, drivers and actuators. The controller model and component sizing remain to be selected and verified.
- Mac StudioLocal AI and vision
- Central controllerCoordination and robot state
- MicrocontrollersSensors and axis control
- Drivers and actuatorsMotion execution
Conceptual diagram of the planned architecture. Hardware integration and performance are still to be validated.
Control needs explicit rules.
The requirements include a hardware stop independent of the AI computer and communication links. Axis limits, fault handling and behaviour when commands are absent form part of control-system design.
05 / ARTIFICIAL INTELLIGENCE
AI, onboard.
The design choice is an onboard Mac Studio M2 Ultra with 64 GB of unified memory, running AI and vision models locally. The objective is operation that does not require cloud services for core functions.
Dialogue, environmental perception and behaviour coordination are development areas. They will be evaluated alongside latency, power consumption, heat dissipation and computing resources. Actual capabilities will be documented when integrated and tested.
The software plan calls for a system developed for this architecture. The OpenSAINT mechanical foundation and the AI work have distinct roles in the project.
06 / THE ROADMAP
One verifiable step at a time.
Sources and organisation
Collection of OpenSAINT references and organisation of the technical archive, retaining original sources.
DocumentedAssembly revision
Component modifications and redesigns. Revision U11 includes two corrected finger segments, assembly reopening and kinematic tests.
CAD checks- NEXT PHASES
Construction and integration
Sizing, manufacturing, assembly, electronics and physical subsystem testing.
To be developed - TOWARDS THE THESIS
AI and experiments
Definition of the research question with the supervisor, function integration and evaluation on measurable tasks.
Research objective
Follow the project in detail.
The journal collects changes and verification results. The first technical entry follows two hand components from geometry correction to assembly checks.
OpenSAINT / Input Inc. was an essential starting point. Simone Renzi’s project includes modifications to many components and the complete redesign of some of them. The renderings were created in Blender with Octane from his Autodesk Fusion assembly and show work in progress. OpenSAINT · Base CAD licence · Laboratory HDRI / Poly Haven · Tool chest / Poly Haven · Bench vice / Poly Haven · Derived renderings: CC BY-NC-SA 4.0. An independent personal project inspired by the robot from Short Circuit.